
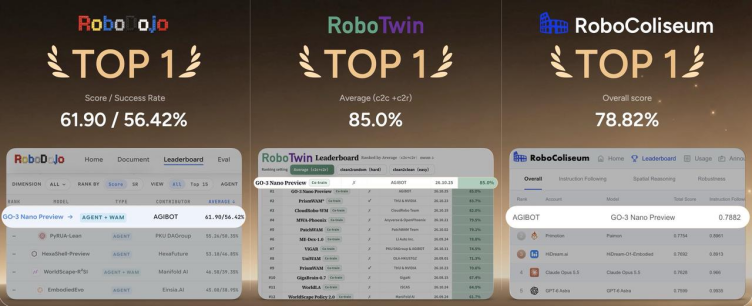
AGIBOT announced GO-3 Preview on October 29, according to its October 30 company release. It describes a World Reasoning Action Model architecture connecting task reasoning, prediction of future states and action generation. The company plans to open-source the model fully by the end of 2026.
For post-training, AGIBOT says it has built the Genie Evolver system around distributed interaction with a hundred physical robots, physics simulation and a world model. The release presents this as a way to update policies from robot experience and send revised models back to physical machines for validation.
Companies in this report
Supplier profiles in the RoboPallas directory
Source: AGIBOT ↗