
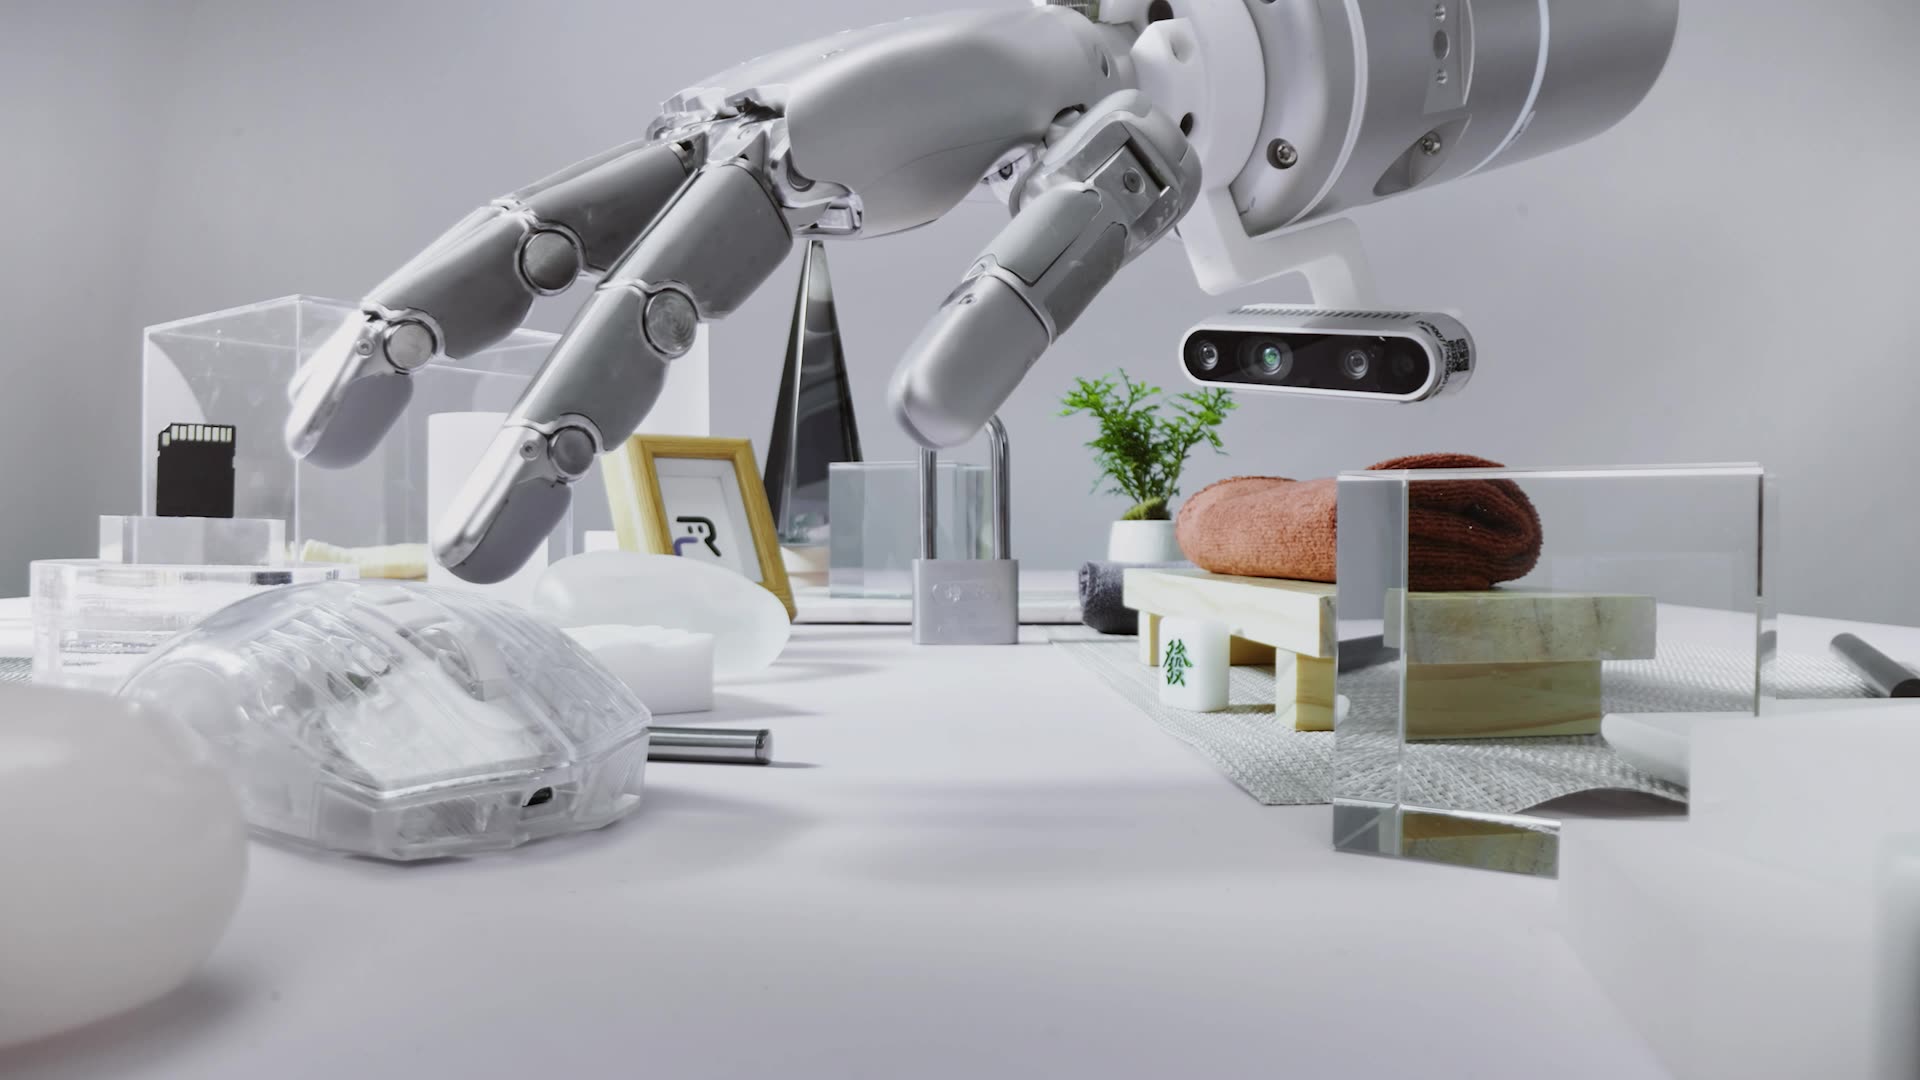
Robbyant has made LingBot-Touch available as a tactile representation model for dexterous robot manipulation. Its project page describes a shared representation intended to transfer tactile experience across hardware platforms and tasks.
The model uses modality-specific tokenizers and a shared Haptic Transformer to process magnetic, piezoresistive and visuotactile recordings. Robbyant says it was pretrained on nearly 5,000 hours of data from tactile gloves and robot hands.
The published pretraining corpus totals 4,983 hours, 464,431 interaction episodes and about 1.33 billion frames across the three sensor types.
The project page lists 26 real-world dexterous tasks and 12 simulated tasks. It presents LingBot-Touch as a reusable feature layer for downstream policies, rather than a complete robot controller.
Companies in this report
Company profiles linked from RoboPallas reports